
I am a Postdoctoral Researcher in robotics and artificial intelligence at The Chinese University of Hong Kong (CUHK), affiliated with the Multi-Scale Medical Robotics Center in Hong Kong SAR. I received my Ph.D. from the Bioinspired Robotics and Medical Technology (BMT) group at CUHK, advised by Prof. Samuel Au.
My current research interests include:
- Safety-aware autonomous surgical systems
- Deformable object modeling, planning, and manipulation
- In-hand object reconstruction and manipulation
News
| Jul 31, 2026 | One IJRR paper, “Actuation-constrained control framework for optimal microswarm navigation with swarm stability guarantee,” has been published. |
|---|---|
| Apr 24, 2026 | One TMech paper, “Hierarchical Deformation Planning and Neural Tracking for DLOs in Constrained Environments,” has been accepted. |
| Oct 20, 2025 | One RAL paper, “Generative 3D State Estimation for DLOs From Partial Observations,” has been accepted. |
| Jul 22, 2025 | Successfully passed my Ph.D. defense at The Chinese University of Hong Kong. Thesis: Learning-based Deformable Linear Object Manipulation in Unstructured Environments. |
| Jul 14, 2024 | One RSS paper, “Homotopic path set planning for robot manipulation and navigation,” has been accepted. |
| Jan 22, 2024 | One RAL paper, “Learning-Based MPC With Safety Filter for Constrained Deformable Linear Object Manipulation,” has been accepted. |
Publications
Selected publications only.
2026
-
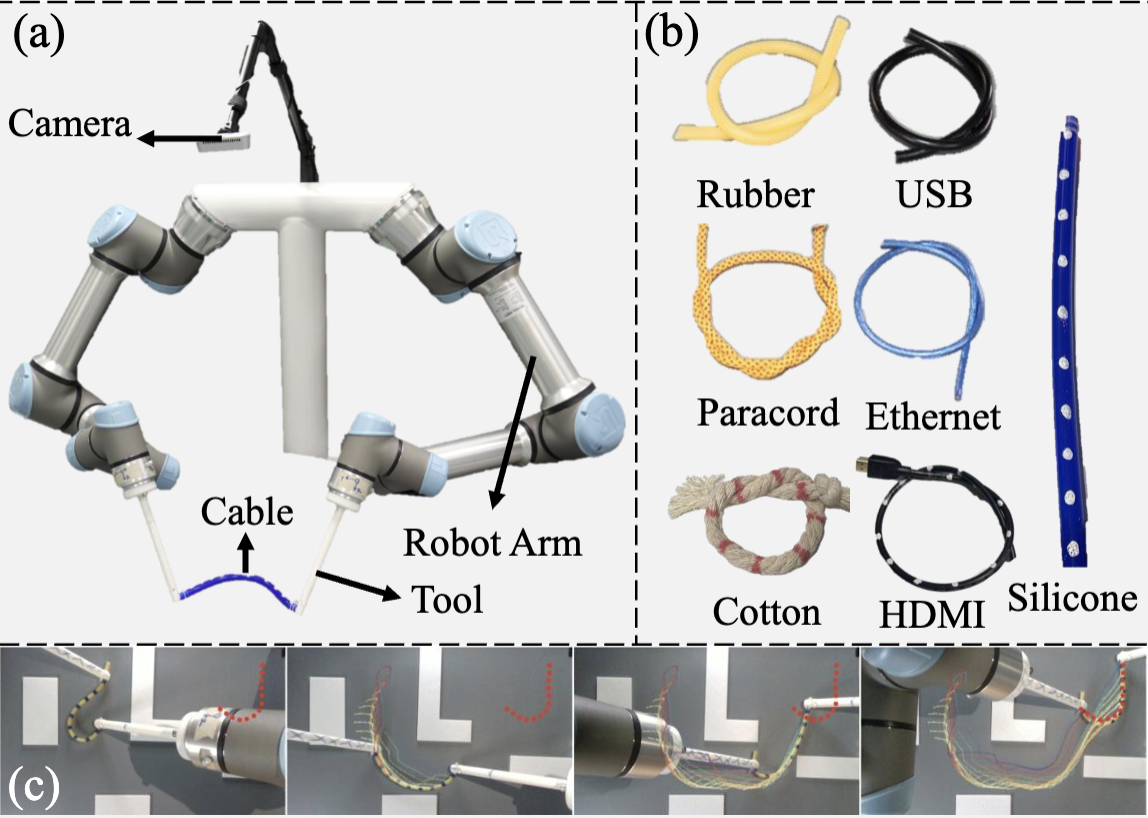 Hierarchical Deformation Planning and Neural Tracking for DLOs in Constrained EnvironmentsIEEE/ASME Transactions on Mechatronics, 2026
- Actuation-Constrained Control Framework for Optimal Microswarm Navigation with Swarm Stability GuaranteeThe International Journal of Robotics Research, 2026
2025
-
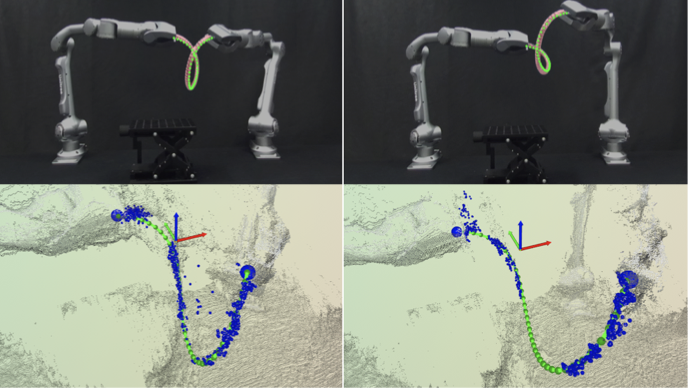 Generative 3D State Estimation for DLOs from Partial ObservationsIEEE Robotics and Automation Letters, 2025
- Learning-Based Motion Controller for Reconfigurable MicroswarmsIn 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025
2024
-
 Homotopic Path Set Planning for Robot Manipulation and NavigationRobotics: Science and Systems, 2024
-
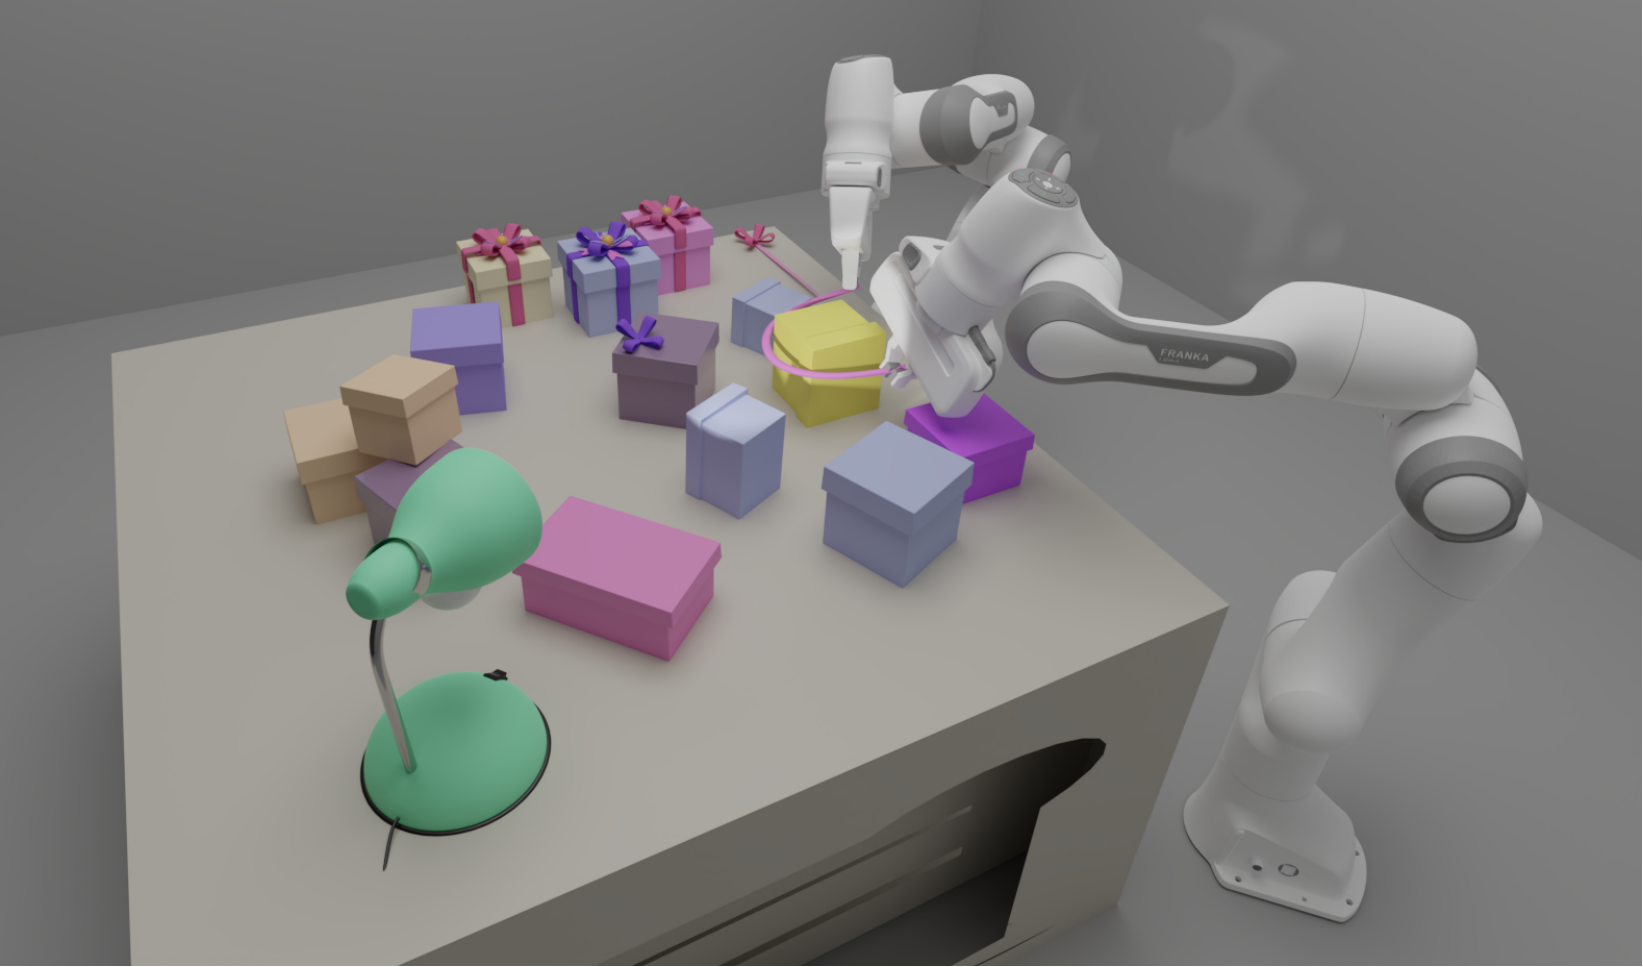 Learning-Based MPC with Safety Filter for Constrained Deformable Linear Object ManipulationIEEE Robotics and Automation Letters, 2024
2023
-
 Bootstrapping Robotic Skill Learning with Intuitive Teleoperation: Initial Feasibility StudyIn International Symposium on Experimental Robotics, 2023
-
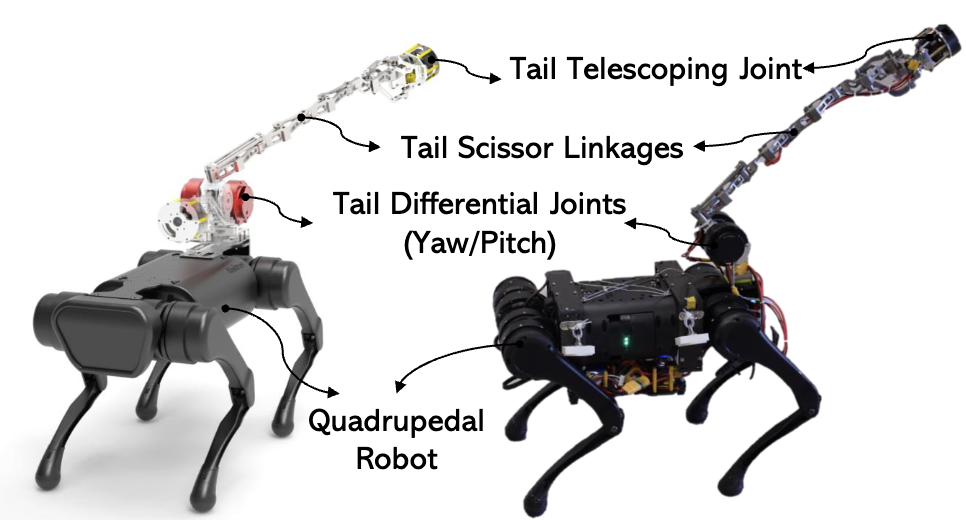 Towards Safe Landing of Falling Quadruped Robots Using a 3-DoF Morphable Inertial TailIn 2023 IEEE International Conference on Robotics and Automation (ICRA), 2023
2021
- Operational Space Control for Planar PA N–1 Underactuated Manipulators Using Orthogonal Projection and Quadratic ProgrammingIn 2021 IEEE International Conference on Robotics and Automation (ICRA), 2021
- Controlling Bending Deformation of a Shape Memory Alloy-Based Soft Planar Gripper to Grip Deformable ObjectsInternational Journal of Mechanical Sciences, 2021
-
 Inequality Constrained Trajectory Optimization with a Hybrid Multiple-Shooting iLQRarXiv preprint arXiv:2109.07131, 2021
Open-Source Projects
- Virtual RCM: QP-based remote center of motion control for general-purpose robot arms.
- Diffusion Planner: Diffusion-based planning for constrained deformable object manipulation.
- Simple Robotic Trajectory Optimization: Single- and multiple-shooting DDP with constraints for motion planning of dynamical systems.
- Gaussian Processes for Robot: Modeling robot dynamics with Gaussian processes.
- Hopping Robot: 2D hybrid-dynamics simulation of a hopping robot with a Raibert controller for forward velocity and hopping height.
- EziTrain: Python utilities that simplify machine learning model training.
Education
2021–2025
The Chinese University of Hong Kong Hong Kong SAR
Ph.D. in Mechanical and Automation Engineering
2019–2021
The Chinese University of Hong Kong Hong Kong SAR
M.Phil. in Mechanical and Automation Engineering
2015–2019
Harbin Institute of Technology Harbin, China
B.Eng. in Mechatronics Engineering
Academic Service
- Reviewer: IEEE Robotics and Automation Letters (RA-L), IEEE International Conference on Robotics and Automation (ICRA), IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
Teaching Assistance
- Advanced Robotics, Engineering Optimization, Fundamentals of Machine Intelligence
Film Photography
Researcher by day, photographer now and then.


Photos are updated occasionally.